Mechanical Design &
Dimensional Engineer
Hi, I'm Leiam Gaudin. Mechanical Engineering student at Purdue University (GPA 3.57, Exp. Dec 2027), previously at Tesla (Dimensional Engineering), Estes Design, and American Water.
Selected Projects & Research
Click any project card to open its high-resolution CAD models, dynamic MATLAB simulations, and testing teardowns.
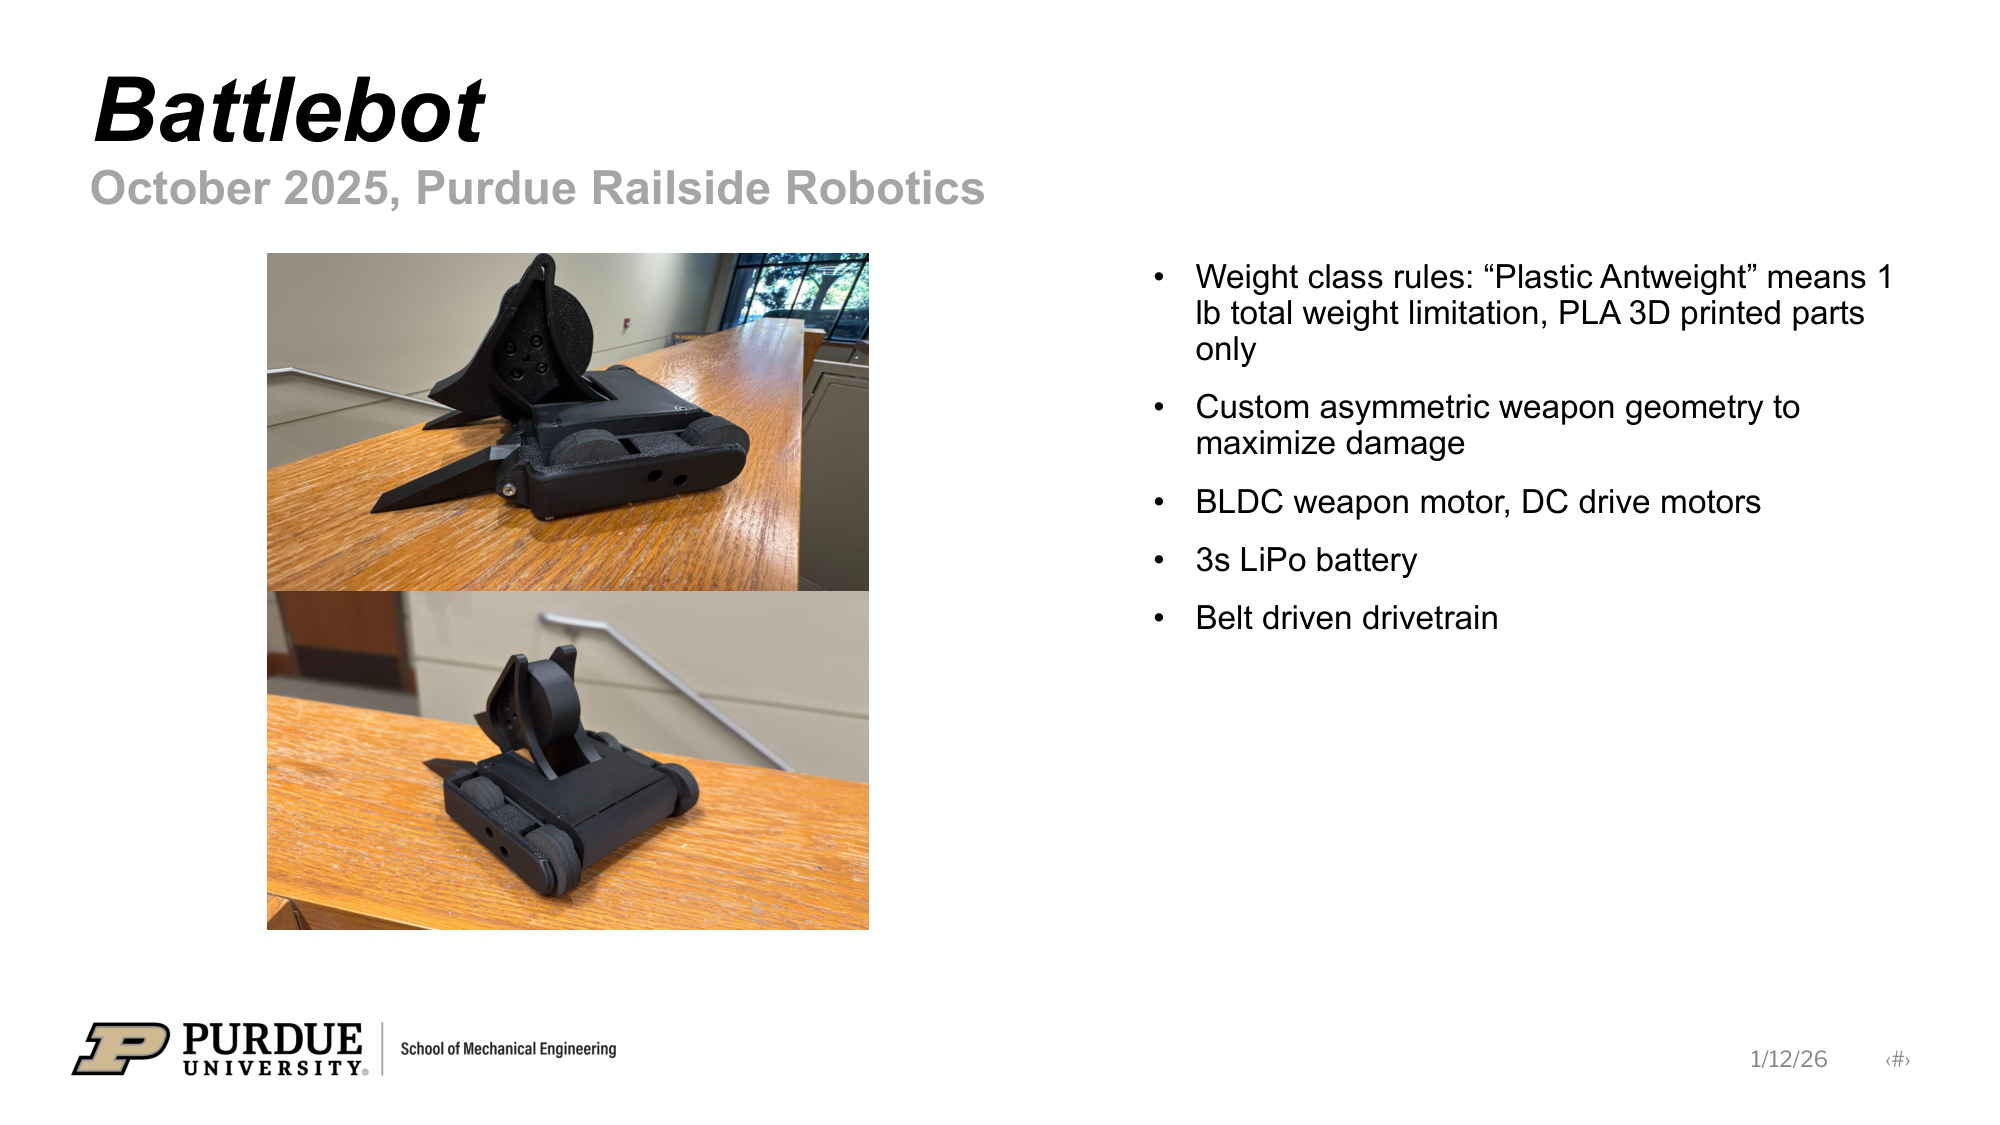
1-lb Combat BattleBot
Designed, engineered, and manufactured a competitive 1-lb Plastic Antweight combat robot featuring a custom asymmetric weapon blade, internal BLDC powertrain, and center-of-mass balancing script in MATLAB. Achieved 1st place in the onboarding tournament.
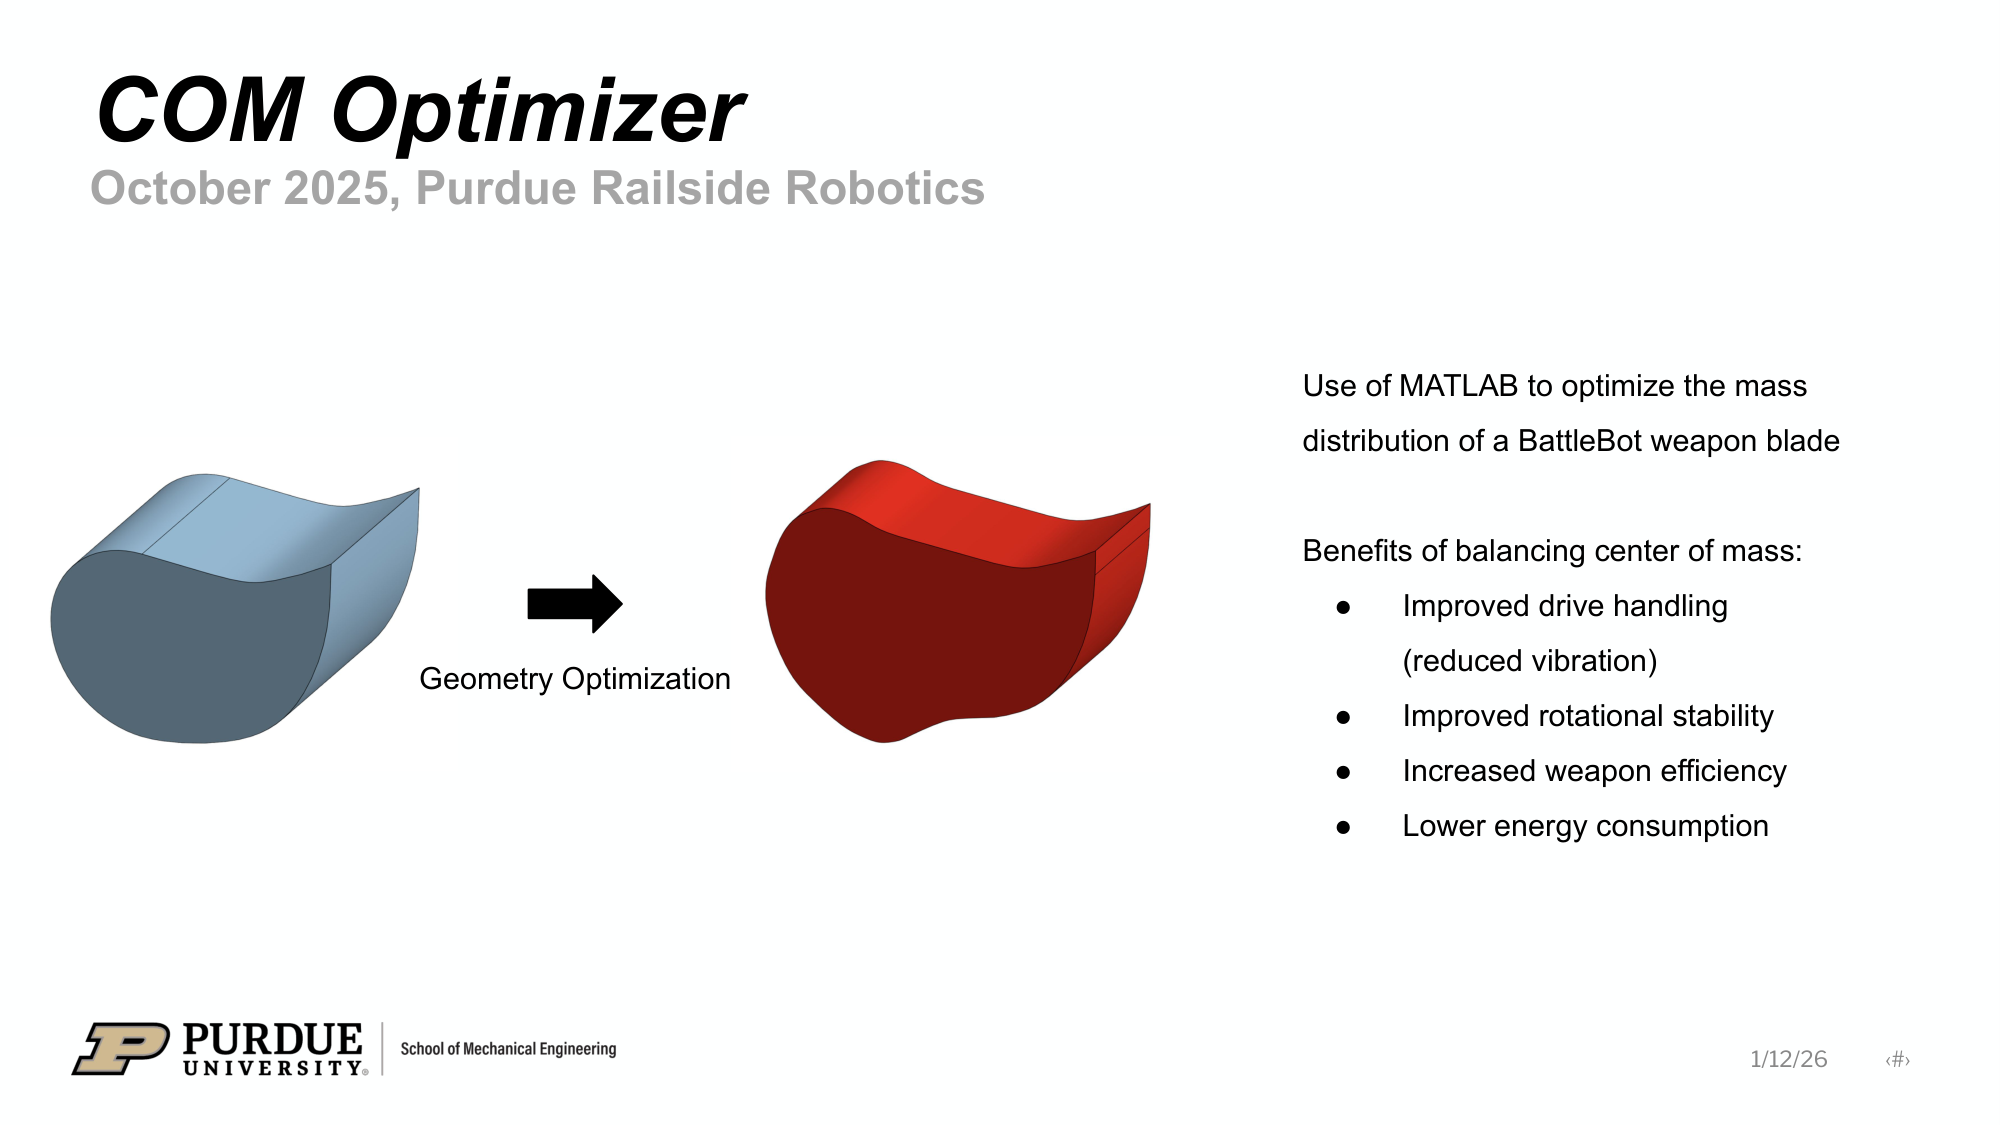
Center of Mass (COM) Blade Optimizer
Developed an algorithmic numerical optimization tool in MATLAB to dynamically rebalance asymmetric spinning combat robot weapons, eliminating severe rotational vibration and optimizing kinetic energy delivery.
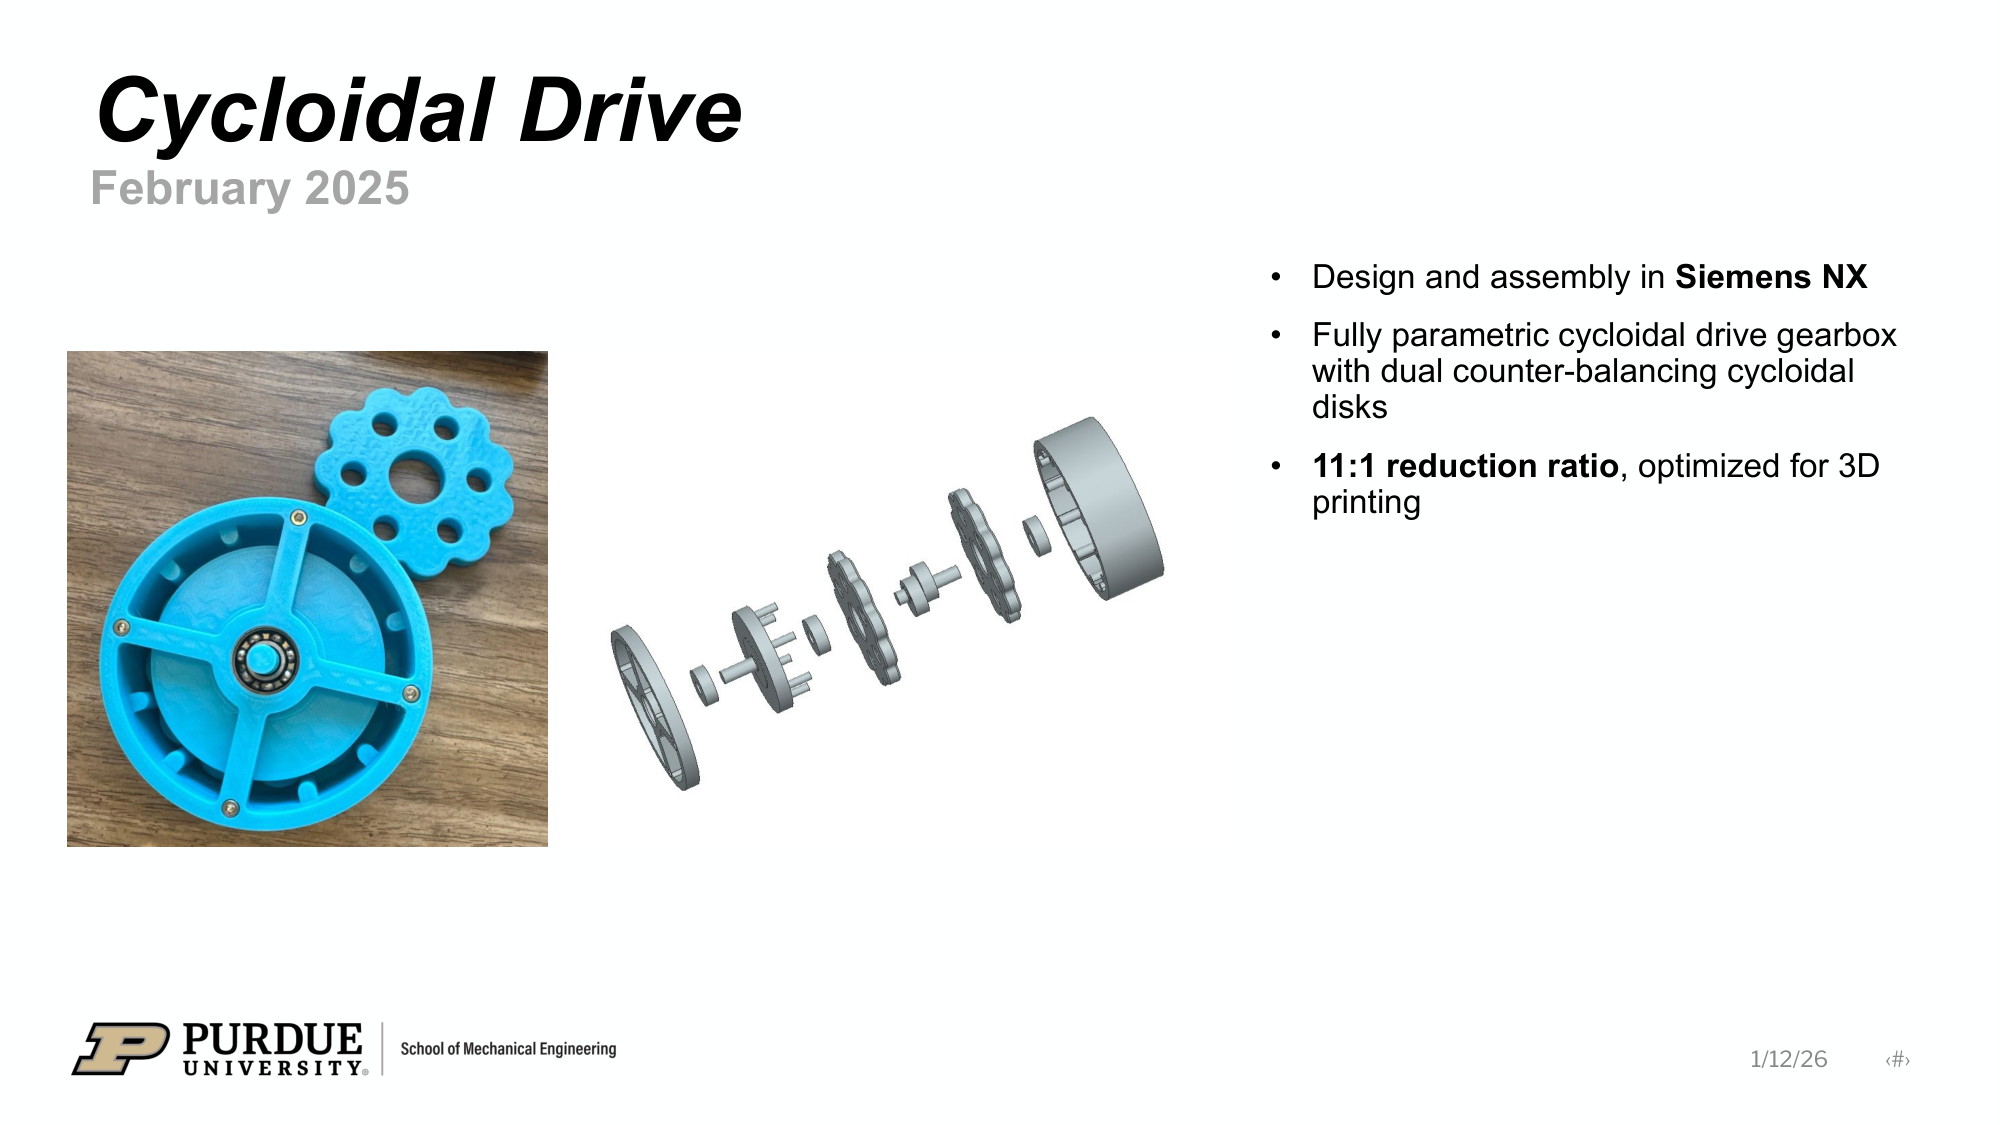
Parametric Cycloidal Drive Reducer
Designed and engineered an 11:1 zero-backlash parametric cycloidal speed reducer in Siemens NX. Modeled with dynamic mathematical law curves and manufactured with precision 3D printing calibrated to 0.02 mm tolerance.
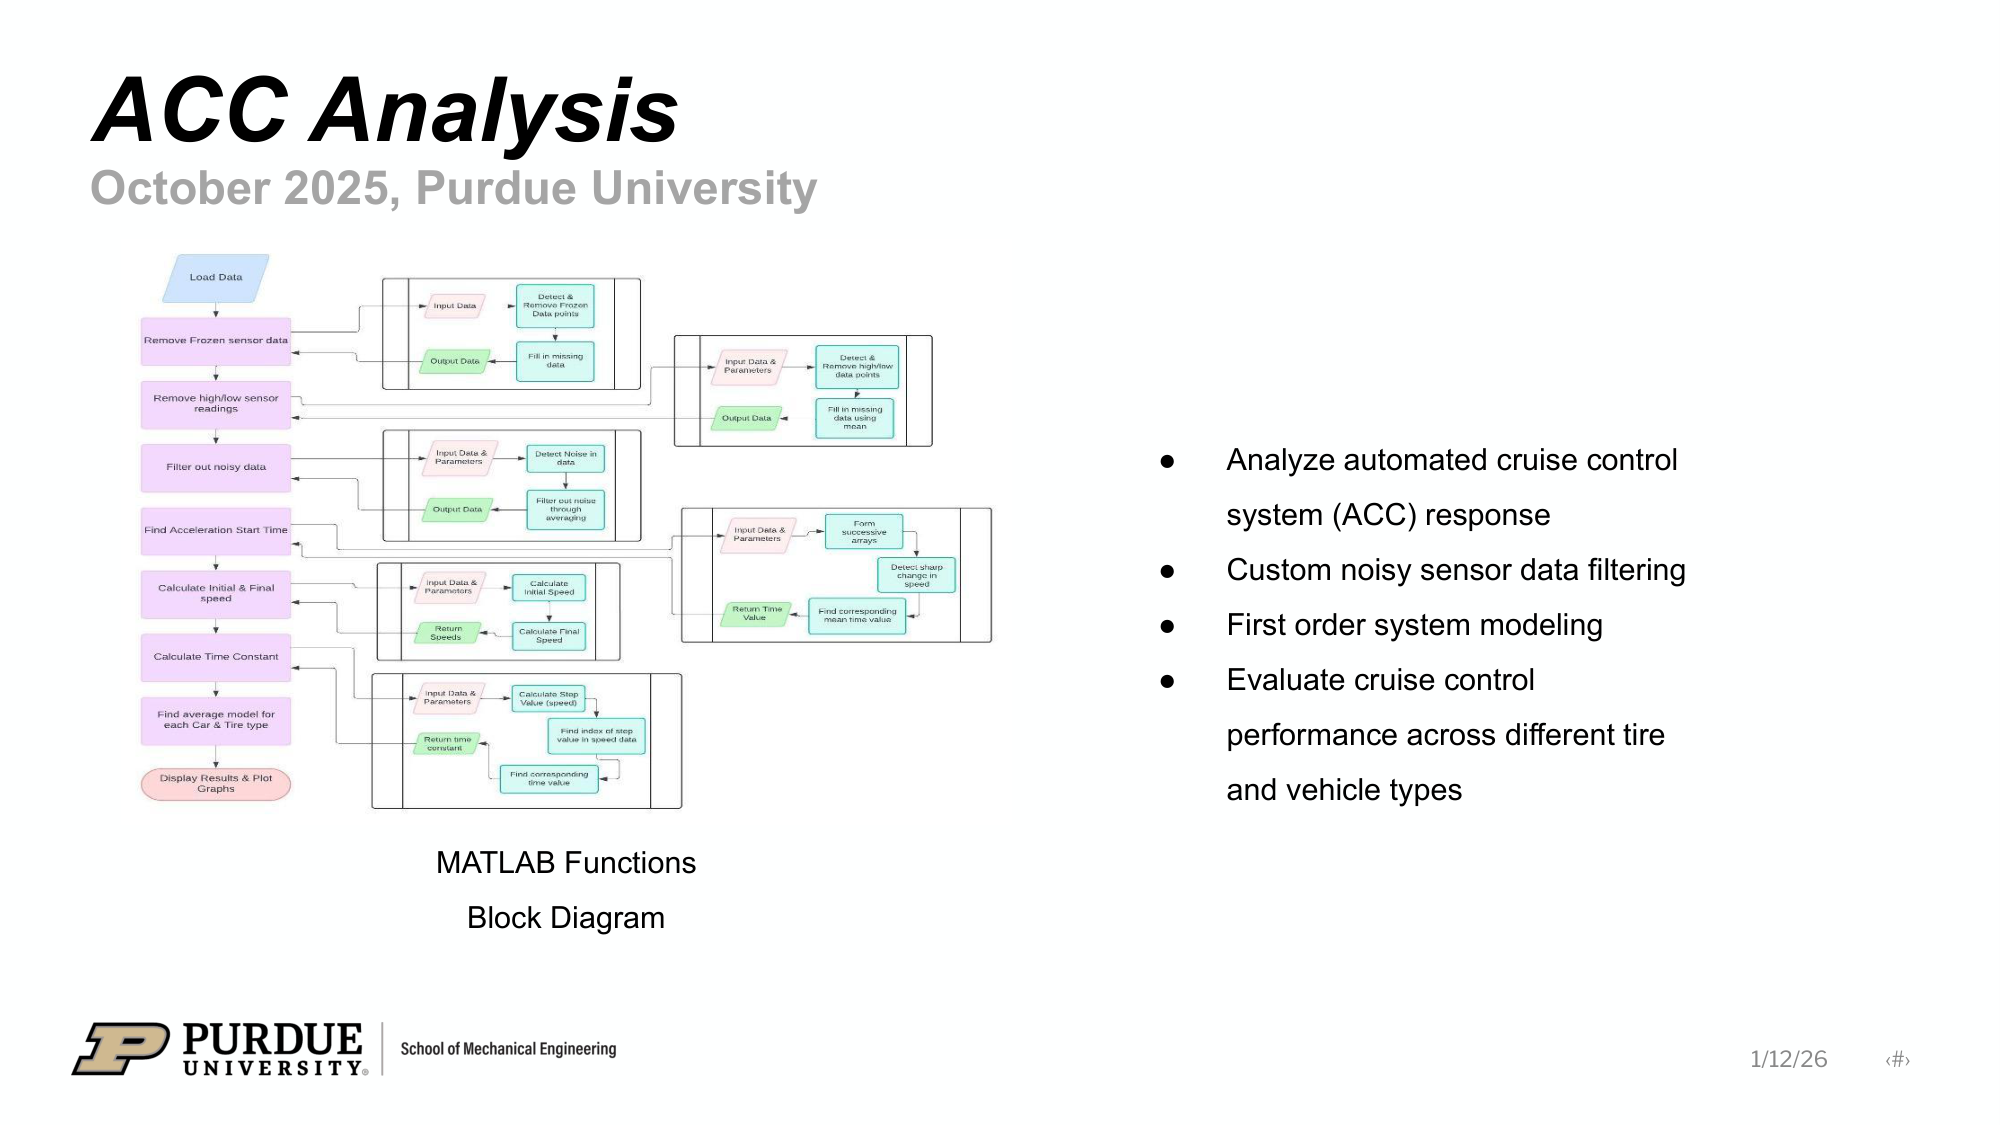
Automated Cruise Control (ACC) Modeling
Engineered a first-order dynamic model and custom sensor filtering algorithm in MATLAB to evaluate adaptive cruise control response under varying vehicle weights, road gradients, and tire compound characteristics.
Purdue Assignment Automation Dashboard
Built a consolidated academic task management web application with a Python backend and clean responsive frontend to scrape assignments across disparate university portals (Brightspace & Gradescope).
CAD & Rapid Prototyping Platform
Built a web platform to showcase and manage freelance engineering drafting, GD&T tolerance analysis, and FDM rapid prototyping services for external clients.
Professional Experience
High-impact engineering co-ops and leadership in dimensional engineering, manufacturing fixtures, and racing powertrain systems.
Mechanical Design Engineer, Dimensional Engineering Intern
- •Improved 3DCS sim tree workflow by 1200% by developing an automation software tool for CATIA, utilizing computer vision.
- •Created a structural beam design alteration that increased Cpk from 0.25 to 2.25 by increasing clearance gap and adding a bracket welded post-assembly to provide 'z-slip' while protecting structural integrity, resulting in 0% out of spec parts (down from 45.33%).
- •Analyzed 10+ critical interfaces on the Tesla Megapack (NE42) using DVA models and Monte Carlo contributor analysis simulations in 3DCS for 3DEXPERIENCE / CATIA.
- •Defined and protected critical dimensional objectives to reach 8-sigma repeatability; collaborated with manufacturing engineers on GD&T datum strategy and fixture optimization to reduce framing station cycle time.
- •Performed 40+ 1-D stack-ups to analyze potential assembly interference issues and advised design engineers.
Engineering Project Management Intern
- •Led multidisciplinary coordination across 4 water main replacement projects, optimizing project scheduling and milestone tracking for stakeholders, contractors, and inspectors.
- •Facilitated project delivery logistics for projects valued at $2M+ through the synthesis of technical documentation and engineering specifications to accelerate review cycles.
- •Managed on-the-fly design tweaks when discrepancies arose between physical piping installations and design schematics.
- •Conducted safety meetings and evaluations during active projects to maintain compliance with corporate safety standards.
Mechanical Engineering Intern
- •Designed 3D printed fixtures and jigs to improve assembly time over heavier metal jigs, cutting assembly time by 4%, boosting OEE, and saving $11,000+ in development costs.
- •Drafted 60+ CAD drawings and applied GD&T with tolerance stack-up analysis on large assemblies to guarantee seamless assembly of sheet metal and hardware.
- •Executed DFM principles in sheet metal, gaining expertise in laser cutting (Salvagnini L3) and precision forming (Amada).
- •Developed a linear actuator and electrical system for a firearms safe door featuring RFID wireless locking and a comprehensive control circuit plan.
Drivetrain Engineer
- •Verified planetary gear tolerances by designing and manufacturing a fixture for CMM scanning, allowing the team to assess viability of gear manufacturing and innovate the carburization process.
- •Collaborated with teammates to revise bolt torque spec calculations for upright oil plate and upper suspension arm after bolt failures, utilizing a Root Cause Analysis (RCA) with Corrective Action.
- •Fabricated high-precision drivetrain and pedal box potentiometer components using manual & CNC mills and lathes.
- •Hands-on assembly of suspension and front uprights (planetary gearboxes) during testing phase to prep the car for competition.
Technical Competencies
Combining hands-on physical manufacturing and advanced dimensional GD&T analysis with custom software automation tools.